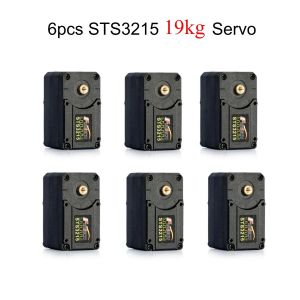
Feetech STS3215 19KG 7.4V Gear Ratio 1:345 Dual Axis TTL String RC Servo Motor for SO-ARM100 Robotic Arm ST-3215-C001 (6pcs)
6pcs Feetech STS3215 19KG 7.4V Dual Axis TTL String RC Servo Motor for SO-ARM100 Robotic Arm for Programming Robot ST-3215-C001 Features STS3215 is 7.4V 19kg serial bus smart servo,adopt plastic case、core motor、metal gearbox、Feetech self researched and developed TTL control board,12 bit high precision magnetic coding sensor. The stall torque is 19kg.cm,can achieve 0-360 degrees any angle controllable,multi-turn continuous operation mode, it can realize the function of setting the middle point with one key,acceleration slow start and slow stop,can feedback position、speed、voltage、current、temperature、load parameters,thus, overload and over-current protection can be realized. It is suitable for application in industrial equipment, robot and Small torque drive application scenarios. Product Details Model:STS3215 Product Name: 7.4V 19KG. Dual axis TTL string servo Storage Temperature Range:-30℃~80℃ Operating Temperature Range: -20℃~70℃ Size: A:45.2mm B:24.7mm C:35mm Weight: 55± 1g Gear type: Copper Limit angle: NO limit Bearing: Ball bearings Horn gear spline: 25T Horn type: Plastic,POM Case: aluminium alloy Connector wire: 150mm ±5 mm Motor: Coreless motor Operating Voltage Range: 6-7.4V No load speed: 0.238sec/60°@6V Runnig current(at no load) : 150 mA@6V Peak stall torque: 19.5kg.cm@6V Rated torque: 6.5kg.cm@6V Stall current: 2000mA@6V Command signal: DigitalPacket Protocol Type: HalfDuplex Asynchronous Serial( ommuni cati on ID range: 0-253 Communication Speed: 38400bps ~ 1 Mbps Running degree: 360° (when 0~4096) Feedback: Load, Position, Speed,nput Voltage,Current
Electronic control Function: 1.Acceleration start stop function: speed and acceleration value can be set, motion effect is more gentle. 2.High precision, 360 degree absolute position 4096 bit precision, the highest position resolution is 0.088 degrees, if the control is 90 degrees, input 4096 / 360 * 90 = 1024, if the control is 180 degrees, input 4096 / 360 * 180 = 2048, so as to calculate. 3.There are four working mode switching (mode 0 position servo, mode 1 speed closed-loop, mode 2 speed open-loop, mode 3 step servo). 1)、Mode 0:Location mode, the default mode. In this mode, 360 degree absolute angle control can be realized. Support acceleration movement. 2)、Mode 1:Speed closed-loop, in the programming interface, the operation mode is set to 1, switch to speed closed-loop mode, and enter the corresponding speed in the speed column to run. 3)、Mode 2:Speed open-loop, in the programming interface, the operation mode is set to 2, switch to speed open-loop mode, and enter the corresponding time in the time column to run. 4)、Mode3:Step mode: in the programming interface, the maximum / minimum angle limit is set to 0, and the operation mode is set to 3. Switch to step mode. Enter the position in the position bar to step towards the target position. Click the position again to continue to step in the same direction. 4、Multi turn mode, 360 degree absolute control and feedback, under the highest accuracy, the absolute position control can be plus or minus 7 turns, but the number of power cycles is not saved, only the absolute position feedback value is retained. 5、One key calibration, 360 degree angle installation at any position, (40 (decimal) address input 128 (decimal)) one key correction current position is the middle (2048 (decimal)). 6、TTL communication level, half duplex asynchronous communication, bus protocol support to adjust read and write parameters, and add synchronous read function (send an instruction to receive the read back instruction from each servo on the bus in turn.) 7、Multiple protections, (overload, overcurrent, overvoltage, overheating, switch setting, condition parameter changing) 1)、Overload protection: through position detection, during the movement from the starting position to the target position, when the current position is detected to be not the target position after encountering the blocking of obstacles, the unloading force lasts for 2S (20% of the default blocking force). Until a new command is triggered, Release protection 2)、Overcurrent protection: through the set current value, check whether the current reaches the set current value. When it reaches the set current value, release the force (the default torque is 0). Until a new command is triggered, Release protection 3)、Over voltage protection: detect the current voltage value. If it exceeds the set voltage value, the alarm will display over-voltage. 4)、Overheat protection: detect the current motor temperature. If the temperature exceeds the set value, the alarm will display overheat. 8:Multiple feedback: 1)Load feedback: the current control output drives the voltage duty cycle of the motor, and the full scale is 1000 = 100% torque output. 2)Current feedback: The servo working current, 1 = 6.5mA 3)Voltage feedback: The servo working voltage,70=7V,0.1V 4)Temperature feedback: internal working temperature of current servo(measuring temperature)。 5)Speed feedback: feedback the speed of current motor rotation, and the number of steps in unit time (per second) 9、Open PID parameters. FEETECH 7.4V 19KG.CM Plastic Case Metal Gear Magnetic Encoder Double shaft TTL Serial Bus Servo

SWEELA
Review
You May Also Like
🇸🇬NestHome🇸🇬 GOLD Mahjong Tiles Set - Size 37 / Animal Tiles / Fei / 160 Tiles / Board Games / Family Gathering
Firefighter Themed Child Costume Fire Truck Police Car Ambulance Cloaks
HONGYUANSHENG | Kids Large Play Kitchen Toy Set Cutting Food
JOOKE | Cute Direct-Ear Rabbit Sleeping Pillow Plush Toy Birthday Gift
Bandai | Anime Bleach Anime Figure Kuchiki Byakuya Kurosaki Ichigo Action Figure Toushirou Figurine Statue PVC Model Collection Toy Gift
[SG Seller] Hand Bell Baby Handbell Musical Instrument Birthday Gifts
Sand Toys Beach Toys for Kids 20PCS Sand Toys Set Beach Trailer Toys Sand Dump Truck Beach Shovel and Rake
ZOUMUBAI | Reusable DIY Flip Card For English Words and Pinyin Learning
Prisoner Cosplay Costume Criminal with Bracelet Stage Performance Costume Prisoner Suit Clothes
Bandai | Random 10/20Pcs Enamel Pin Brooch Set Anime & Cartoon Surprise Delivery Wishing Gift Metal Badge for Backpack Fans Collection
WLtoys XK K170 Black Hawk 2.4GHz 4CH RC Helicopter 6Axis Gyro Optical Flow One Key RTF 4-Blade Brushless Flybarless Toy for Kids